On Queer Sex Robots

The article “Who Queered the Sex Robot? Notes on Attribution and Conceptual History” by Oliver Bendel, published in Philosophy & Technology on June 10, 2026, is now available Open Access and can be read and downloaded free of charge. An article titled “Queering Sex Robots Beyond Diversifying Design? Insights from Queer Lacanian Psychoanalysis and New Materialism” by Maaike van der Horst and Anna Puzio was published in the journal Philosophy & Technology in March 2026. Surprisingly, it does not reference several works that are highly relevant to the topic, including publications by Tanja Kubes and Oliver Bendel. As a result, some of the article’s claims to originality appear less convincing than they might otherwise have been. Following an exchange with one of the journal’s editors, Luciano Floridi, Oliver Bendel therefore submitted a commentary, which was published in Philosophy & Technology on June 10, 2026. From the abstract: “This commentary discusses Maaike van der Horst and Anna Puzio’s article ‘Queering Sex Robots Beyond Diversifying Design? Insights from Queer Lacanian Psychoanalysis and New Materialism’. While acknowledging the article’s valuable contribution, particularly its integration of Queer Lacanian Psychoanalysis and New Materialism, the commentary argues that its account of prior scholarship is incomplete. Several key themes and proposals presented as novel – including critiques of humanoid mimicry, new-materialist approaches to sexuality and technology, queer design concepts, relational ontology, and transformative sex robot forms – had already been developed in earlier work by Tanja Kubes and Oliver Bendel. The omission of these contributions affects assessments of originality, the reconstruction of the field’s intellectual development, and the allocation of scholarly credit. The commentary therefore calls for a more comprehensive scholarly genealogy of queer and new-materialist approaches to sex robots and argues that careful citation practices are essential to maintaining the integrity of academic discourse.” The article “Who Queered the Sex Robot? Notes on Attribution and Conceptual History” can be accessed at link.springer.com/article/10.1007/s13347-026-01123-3.

ICSR 2027: Key Dates Announced

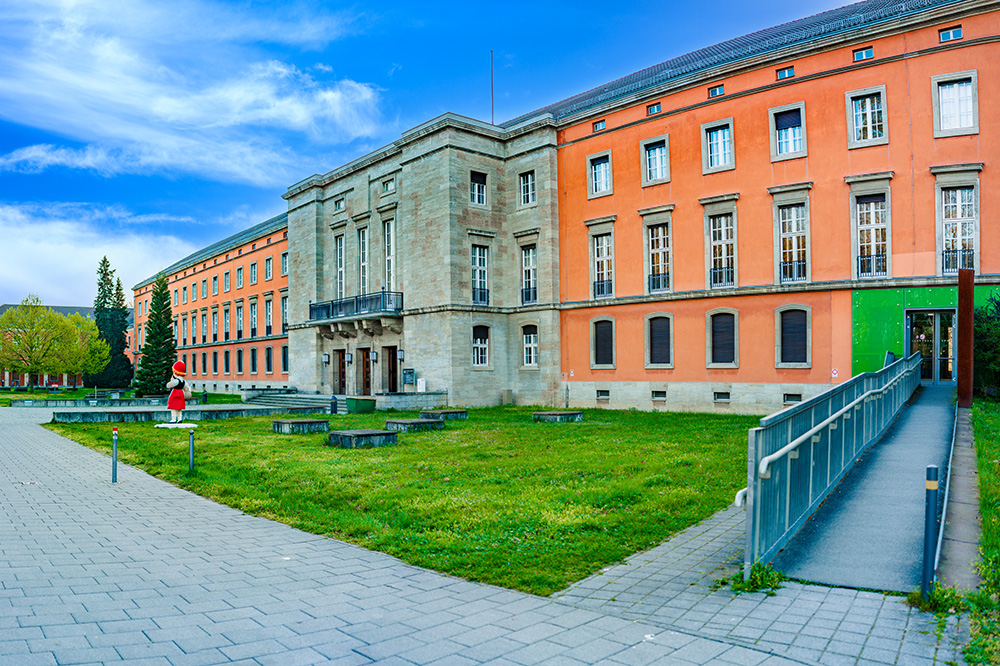
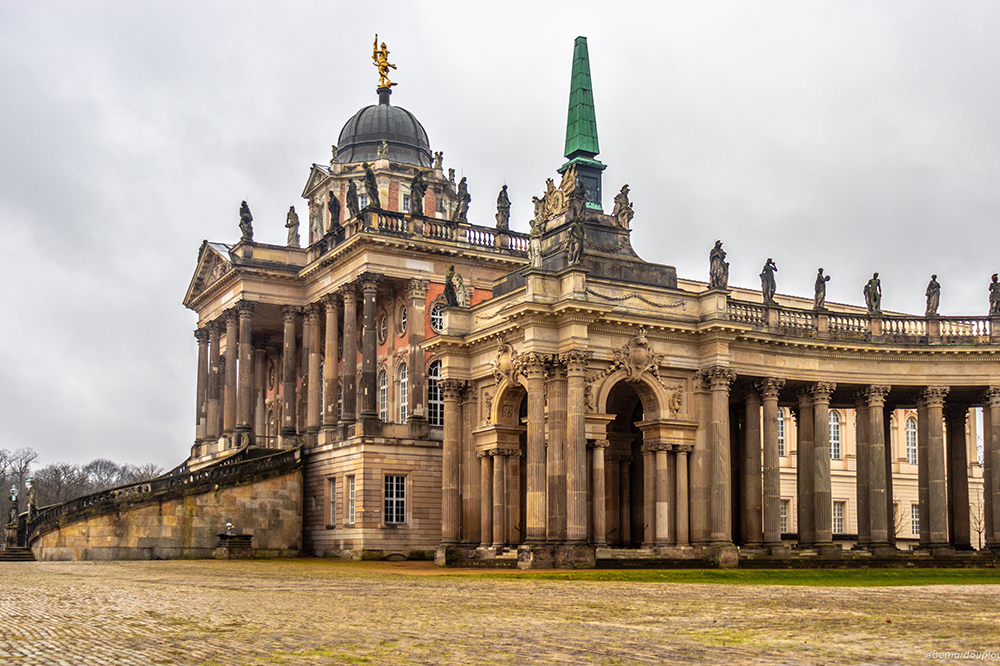
The 19th International Conference on Social Robotics (ICSR + Health 2027) will take place in Potsdam, Germany, from July 25 to 28, 2027. ICSR is the leading international forum that brings together researchers, academics, and industry professionals from across disciplines to advance the field of social robotics. Under the theme “ICSR + Health,” the 2027 conference will place a special focus on assistive and rehabilitation robotics, care, mental health and companionship, healthy aging, and the clinical, ethical, and societal questions associated with these applications. A particular emphasis will be placed on involving people directly affected by the use of social robots in healthcare and caregiving settings, including physicians, nurses, caregivers, patients, and people in need of care. Their perspectives and practical experiences will contribute to discussions on how social robotics can address real-world needs and challenges. Contributions from all areas of social robotics are welcome, reflecting the broad and interdisciplinary scope of the conference. The key submission deadlines have now been announced: Workshop and special-session proposals are due on January 15, 2027, followed by the paper submission deadline on February 15, 2027. Notifications of acceptance will be sent out on April 15, 2027, and the deadline for camera-ready papers is May 15, 2027. The General Chairs are Dr. Katharina Kühne of the University of Potsdam and PECoG, Prof. Dr. Ilona Buchem of Berlin University of Applied Sciences (BHT), and Prof. Dr. Oliver Bendel of the FHNW School of Business. The General Co-Chair is Prof. Dr. John-John Cabibihan of Qatar University. Further details will be published soon on the official conference website at icsr2027.org (Photo: University of Potsdam/Ernst Kaczynski).

Kawasaki Unveils Home Leo

Japanese technology giant Kawasaki Heavy Industries has unveiled Home Leo, a dog-like robot designed to assist older adults in their daily lives. The Japan Times reported on the development on October 7, 2026. The prototype, presented in Tokyo on October 6, 2026, uses artificial intelligence to communicate with people, perceive its surroundings, make decisions based on the situation, and act autonomously. Home Leo is designed to provide companionship, help its owners with everyday tasks, and watch for potential hazards. By continuously learning individual preferences and habits, the robot is expected to adapt to each user’s needs. In the future, it could also detect falls, changes in health conditions, or fire hazards and alert family members or caregivers. According to the Japan Times, Kawasaki President Yasuhiko Hashimoto demonstrated the robot’s capabilities during the presentation by asking it where his smartphone was. Home Leo replied that the device was on the table, retrieved it, and handed it to its owner. Kawasaki plans to launch the robot in the Japanese fiscal year 2028 and is collaborating with government agencies, medical institutions, nursing care organizations, and AI companies on its further development. The goal is to enable older adults to live independently and safely in their familiar surroundings for as long as possible.

Kumo Joins the Social Robots Lab

Since September 2026, a gray Booboo has been part of Prof. Dr. Oliver Bendel’s privately funded Social Robots Lab. Alternative names include Boo Boo, BooBoo, and Cupboo AI Robotic Pet. A black Booboo had already been living there since July 2024, but in July 2026 it traveled to the University of Potsdam to spend some time there. Genmoor writes on its website: “Boo Boo is not just a toy. It is also the king of the planet Lonely …” (Genmoor website). According to the manufacturer, Boo Boo’s movements are made possible by a complex control system. “Therefore please be kind to Boo Boo, it is not an ordinary robotic pet. It could give you different responds according to your interaction.” (Genmoor website) Other robots and figures at the Social Robots Lab include Unitree Go2, Alpha Mini, Cozmo, Vector, AIBI, Eiliko, Furby, Tamagotchi, Hugvie, and HUGGIE. NAO and Pepper have also visited repeatedly, as revealed in a 2023 3sat documentary. According to its own description, the Genmoor Group is an “exclusive group for daring futurists who love tech-psychology” (Genmoor website). The company was founded in Hangzhou, China, in 2020. The black Booboo is particularly popular in Oliver Bendel’s elective modules on social robotics. The gray one will introduce itself in February. Student Sushana Yogeswararasah, a former participant, has already named it Kumo – Japanese for “cloud” or “spider”, depending on the context and the characters used.

A Robot Shaped Like a Duck

Ducks have repeatedly served as models for animal-like automata and robots, particularly in France and Japan. The European country is actually known for its cruel treatment of these animals, but it also seems to have a soft spot for them. Jacques de Vaucanson’s mechanical duck, built in 1738/1739, became famous. Born in Grenoble in 1709, the gifted engineer died in Paris in 1782. Pollen Robotics is based in Bordeaux. The company is now owned by Hugging Face, which is headquartered in Manhattan. With Microduck, it has introduced a compact robot designed as an experimental platform for physical AI and reinforcement learning. Standing around 25 centimeters tall and weighing less than 800 grams, it is comparatively small. Its hardware includes 15 motors, a camera, a LiDAR sensor, two IMUs (sensors that measure acceleration and rotational motion), microphones, and speakers. A movable beak also allows the little duck to grasp small objects. It can walk, sit down, stand up, pick up objects, and perform various movement sequences. It can even glide along on optional inline skates. After a fall, it can get back on its feet independently from a variety of positions. The main focus, however, is not so much on using Microduck as a conventional robotic toy, but rather on experimenting with a learning AI system. Movements and behaviors can first be trained in a simulation and then transferred to the physical robot. This so-called sim-to-real approach enables hands-on experimentation with reinforcement learning and robotics. Pollen Robotics provides the SDK, simulation environment, and reinforcement-learning software as open source. Microduck thus combines a comparatively accessible hardware platform with state-of-the-art methods in AI and robotics research. More information is available at pollen-robotics.com.

Oliver Bendel Joins the University of Potsdam as Visiting Scholar

Prof. Dr. Oliver Bendel of the FHNW School of Business will be a visiting scholar at the University of Potsdam from September 1, 2026, to August 31, 2027. He considers himself a philosopher of technology, focusing on technology ethics and emerging fields of applied ethics, particularly information ethics, robot ethics, and machine ethics. In information ethics and robot ethics, he takes an empirically informed or empirically grounded approach that remains close to the subject matter. Ethical judgments are preceded by as precise an empirical and technical analysis as possible: The first step is to determine the specific characteristics of a given system, the functions it provides, the data it processes, and the effects it produces. Only on this basis are normative questions concerning issues such as informational autonomy, privacy, responsibility, or well-being examined. Normative claims are not derived from description alone, and empirical findings and normative premises remain clearly distinguishable. In machine ethics, Bendel complements this approach with a constructive-experimental methodology. He develops and tests prototypes himself, including specialized chatbots, voice assistants, and household robots in which moral rules are implemented. Here, construction serves as a method of inquiry: Its initial purpose is to demonstrate whether and how particular moral rules can be operationalized and implemented technically. The resulting artifacts are then systematically examined to reveal the possibilities, limitations, contradictions, and unexpected consequences of their implementation. This creates a feedback loop involving ethical conceptualization, technical construction, empirical testing, and ethical reflection. Overall, this methodology can therefore be characterized as an empirically grounded and constructive-experimental approach to technology ethics and related fields of research. Since 2022, Oliver Bendel has also been an associated researcher with the Potsdam Embodied Cognition Group (PECoG) at the University of Potsdam.

The Red Attraction Effect

The Robophilosophy 2026 conference took place from August 11–14, 2026, at University College Dublin (UCD) in Dublin, Ireland. Held under the theme “Connected Futures – Nature, Robots, and Society”, the seventh installment of the international conference series brought together researchers from a wide range of disciplines to explore how robotics and artificial intelligence are transforming human societies and the natural world. On the first day of the conference, Katharina Kühne presented the paper “No Red Romance for Robots? Investigating the Red Attraction Effect in Humanlike Robots”, authored by Emma Luisa M. Waller, Diana P. Ebenburger, Oliver Bendel, Martin Fischer, and herself. The study investigates whether the red-attraction effect known from research on human perception also occurs when people evaluate humanlike robots. From the abstract: “The color red has been shown to positively influence ratings of attractiveness and willingness to spend money (e.g., on a date), while having no effect on other perceptions, such as likeability. In an online study, we aimed to conceptually replicate the red-attraction effect using humanoid robots as stimuli. Forty-four heterosexual female participants evaluated 16 images of medium and highly humanlike robots on attractiveness, likeability, trustworthiness, and willingness to spend money to rent the robot. We found no evidence of a red-attraction effect. Female-looking robots received higher ratings overall. These findings have implications for robot design and suggest that basic cues, such as color, may not operate in the same way for robots. Instead, humanoid robots may constitute a distinct category but still be perceived as social agents.” The proceedings, containing all conference papers, are expected to become available in late 2026.

ICSR + Health 2027 at University of Potsdam

The 19th International Conference on Social Robotics (ICSR + Health 2027) will take place in July 2027 in Potsdam, Germany. ICSR is the leading international forum that brings together researchers, academics, and industry professionals from across disciplines to advance the field of social robotics. Hosted by the University of Potsdam, ICSR + Health 2027 will provide an international platform for scientific exchange, interdisciplinary collaboration, and innovation at the intersection of social robotics and health. The conference welcomes researchers, practitioners, industry partners, and students from around the world working in areas such as social robotics, embodied AI, human–robot interaction, cognitive science, healthcare, psychology, rehabilitation, design, ethics, and related disciplines. Participants will have opportunities to present their research, propose workshops or symposia, take part in the Grand Challenge, volunteer, or support the conference as sponsors. The General Chairs are Katharina Kühne of the University of Potsdam and the Potsdam Embodied Cognition Group (PECoG), Ilona Buchem of Berlin University of Applied Sciences (BHT), and Oliver Bendel of the FHNW School of Business (also associated researcher at the PECoG). The General Co-Chair is John-John Cabibihan of Qatar University. Further information, including calls for papers, workshops, the Grand Challenge, volunteering opportunities, sponsorship packages, registration details, and the exact conference dates, will be announced on the conference website: icsr2027.org.

More Than Emotional Design

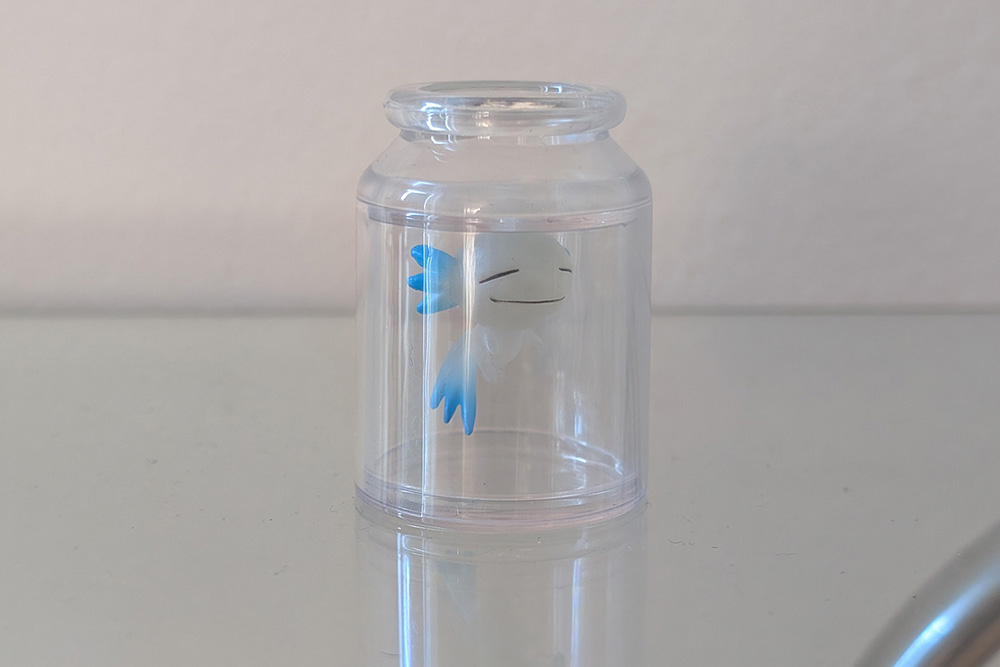
Most design is evaluated by how well it solves a problem. But some of the most memorable objects are not designed to maximize efficiency – they are designed to invite a relationship. Oliver Bendel believes this deserves its own name: Relational Object Design. Unlike Emotional Design, which focuses on how a product makes us feel, Relational Object Design focuses on the object itself as a potential relationship partner. Takashi Murakami’s Rumble-kun in a Jar is a beautiful example. The small axolotl-like creature sits quietly inside a transparent jar. It has no function, no movement, and no intelligence, yet it immediately feels alive. Its gentle expression and childlike proportions encourage us to care about it rather than simply look at it. The same philosophy can be found in the work of Yukai Engineering. Products such as Qoobo, Mirumi, and Nekojita FuFu are not primarily tools; they are companions with distinct personalities. Their value lies less in what they accomplish than in the emotional bond they encourage. This perspective also offers an interesting lens on social robotics. Robots such as AIBO, Eiliko, or Paro are often discussed in terms of artificial intelligence and social interaction, but perhaps the deeper question is simpler: what is the minimum amount of design required for a person to perceive an object as a companion? Murakami’s sculpture suggests that the answer may be surprisingly little. Sometimes a peaceful smile is enough.

Little Blowing Bear

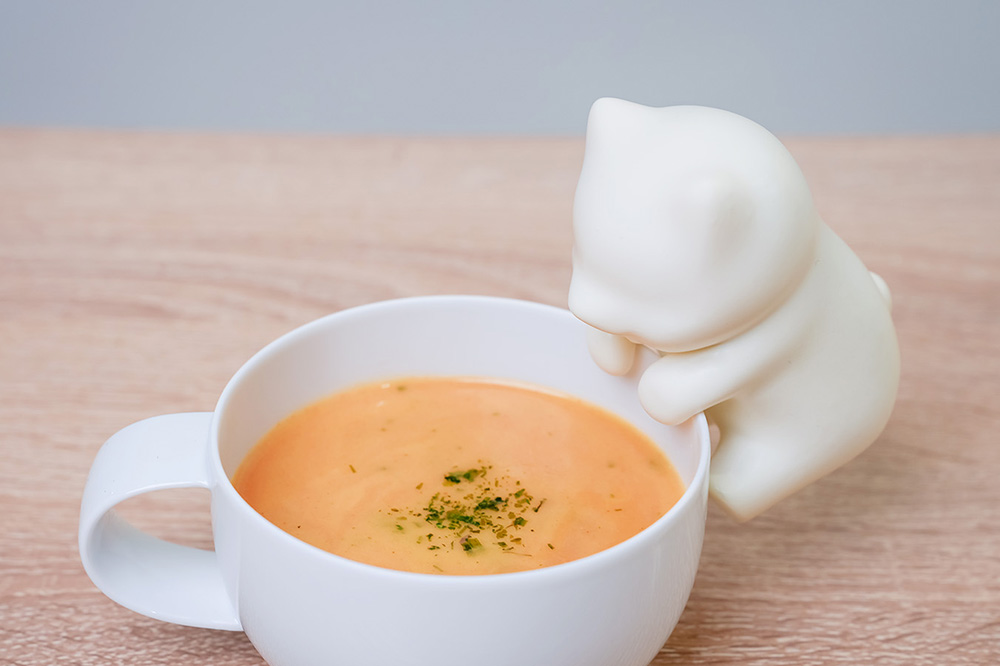
As Publicity Chair of ICSR + Art 2026, Oliver Bendel had the opportunity on the third evening to choose between two gifts, one larger and one smaller. Since he had traveled to London with only carry-on luggage, he opted for the smaller one. When he unpacked the cardboard box back home in Zurich, out popped a little bear. Pressing its stubby tail causes it to blow air through its mouth. In this way, it can cool down hot drinks and hot soups. The philosopher of technology tried it out on his terrace. The little bear blew what seemed like a hole right into his coffee. Its name is, by the way, Nekojita FuFu, and it is – like Qoobo and Mirumi – from Yukai Engineering.T he Berlin Bear is the heraldic animal of Berlin and has adorned the city’s coat of arms for centuries. Just outside Germany’s capital lies Potsdam. The city is best known for its magnificent palaces, beautiful gardens, and its important role in German and European history. It is home to the University of Potsdam as well as several renowned research institutions, including the Max Planck Institute for Gravitational Physics. About 6 kilometers outhwest of Potsdam, in the village of Caputh (part of the municipality of Schwielowsee), stands the Einstein House. The famous physicist had this modest wooden house built in 1929 based on plans by the architect Konrad Wachsmann. Einstein and his family spent their summers there, and he worked there until the end of 1932. The University of Potsdam will host ICSR + Health 2027, where Dr. Katharina Kühne and the Potsdam Embodied Cognition Group (PECoG) will welcome the community with open arms. Incidentally, Potsdam’s coat of arms features a red eagle on a silver field (Photo: Yukai Engineering).