Keynote Speakers of ICSR + Art 2026
The 18th International Conference on Social Robotics (ICSR + Art 2026) will take place in London, UK, from 1–4 July 2026. ICSR is the leading international forum that brings together researchers, academics, and industry professionals from across disciplines to advance the field of social robotics. This year’s conference will feature three distinguished keynote speakers whose work is shaping the future of artificial intelligence, robotics, and human-robot interaction. Hatice Gunes, Professor of Affective Intelligence and Robotics at the University of Cambridge, is internationally recognised for her pioneering research on affective computing, multimodal intelligence, and socially aware AI systems, with a strong emphasis on ethics, fairness, and wellbeing in robotics. Jean Oh, Associate Research Professor at Carnegie Mellon University and Director of the roBot Intelligence Group, is known for her work on collaborative robots, social navigation, and creative physical AI, focusing on developing robots that learn, adapt, and work safely alongside humans in shared environments. Nicolas Heess, Research Scientist and Director at Google DeepMind, leads cutting-edge research on general-purpose robotics and embodied AI, exploring how advances in machine learning, perception, and motor control can bring intelligent robots into the physical world. Together, these keynote speakers represent the forefront of research and innovation driving the next generation of social robotics. Further information on the keynote programme is available at: icsr2026.uk/keynote/.

Robot Dog Helps Blind Navigation

According to a Golem article published on April 12, 2026, researchers at Binghamton University have developed an AI-powered robotic guide dog designed to assist blind people through spoken interaction. Unlike traditional systems that rely on leash signals, the robotic dog uses large language models to understand voice commands, suggest different route options with estimated travel times, and verbally describe surroundings while guiding its user. As it moves, the robot continuously explains nearby hallways, obstacles, and environmental details to improve situational awareness. In tests with seven legally blind participants navigating an office environment, users responded very positively and especially appreciated the combination of route planning and real-time commentary. The research team plans to further improve the robot’s autonomy and expand testing in both indoor and outdoor settings, highlighting the technology’s potential as a future alternative or supplement to traditional guide dogs. An important practical consideration will also be how real dogs react to the robotic guide dog. This was examined in the Robodog project by Prof. Dr. Oliver Bendel and his student Selina Rohr.

SAGA Conference Program

The upcoming “SAGA: Sexuality and Generative AI” symposium, taking place on April 30, 2026 at the Université du Québec à Montréal, explores how generative AI is reshaping intimacy, desire, relationships, and sexual expression. The first block, titled “Societal Impacts”, brings together a set of talks that examine how emerging technologies are already influencing human connection and cultural norms. Brian Willoughby (Brigham Young University, United States) opens with “Engagement with Romantic AI: Implications for Young Adult Dating and Relationships”, addressing how AI companions may alter expectations and behaviors in modern dating. Arnaud Anciaux (Université Laval, Canada) follows with “Toward a Great Bypass? Property, Consent, and Value Creation in AI-Generated Sexual Content”, focusing on legal and ethical questions around ownership and consent. Émilie Gaudet (Université de Montréal, Canada) contributes “AI-Generated Pornography and Problematic Pornography Use”, exploring the psychological and societal risks associated with synthetic sexual media. Finally, Oliver Bendel (FHNW School of Business, Switzerland) looks ahead in “Physical AI and the Future of Intimacy”, considering how embodied AI systems could transform intimate relationships. The program also features “Panel 1 – Technological Solutions to the Challenges of AI”, with contributions from Sophie Mortimer (UK Revenge Porn Helpline, United Kingdom), Alex Georges (AetherLab, United States), and Madelaine Thomas (Image Angel, United Kingdom), who discuss practical responses to harms such as non-consensual content and digital abuse. Overall, the symposium is structured into four thematic blocks and includes two panels, offering a compact yet wide-ranging exploration of one of the most sensitive and rapidly evolving intersections of technology and human life. The SAGA conference program is now available online and can be downloaded here.

From CLEANINGFISH to Gillbert

A student at the University of Surrey proposed a fish-like robot called Gillbert in the context of a university robotics contest, suggesting a system that could move through water and capture microplastics using a gill-inspired filter. The concept was subsequently developed into a 3D-printed research prototype by a university team. The robot mimics fish locomotion via a flexible tail and is designed to collect particles of up to around 2 mm, primarily for monitoring and experimental purposes rather than large-scale cleanup. The project was published as open source. The idea follows earlier conceptual work such as the CLEANINGFISH design study by Prof. Dr. Oliver Bendel (2014), which envisioned small robotic fish operating individually or in swarms to remove plastic and debris from aquatic environments and transport it to collection points, including objects located on the ground. This concept was further examined in 2015 within a project at the University of Applied Sciences and Arts Northwestern Switzerland (FHNW), where increasing plastic pollution in seemingly clean waters and its ecological and human impact were analyzed. Oliver Bendel and his student concluded that robotic fish could interfere with aquatic life and were not sufficiently efficient for practical large-scale deployment, while also raising questions in machine and technology ethics. Gillbert can be understood as a contemporary experimental continuation of these earlier ideas under improved technological and collaborative conditions.

Robophilosophy 2026 Now Open for Registration

The Robophilosophy Conference 2026 (RP2026), titled “Connected Futures – Nature, Robots, and Society”, will take place August 11-14, 2026, in Dublin, Ireland, bringing together researchers from across disciplines to examine how robotics and artificial intelligence are reshaping human societies and the natural world. As robotic systems become increasingly embedded in everyday life, the conference aims to foster dialogue between fields ranging from social robotics, computer science, and human-robot interaction to the humanities, social sciences, law, economics, and environmental research. Central questions include how robotic technologies can uphold human dignity and social justice, how legal systems must adapt to autonomous decision-making, and whether robots can contribute to sustainability rather than accelerate ecological decline. The event marks the seventh installment in the Robophilosophy conference series and features plenary speakers such as Lynne Baillie, Ryan Calo, Hideki Kajima, Arno Klein, Bertram Malle, and Shannon Vallor. Importantly, the submission deadline for research papers, posters, and artistic contributions has been extended to March 15, 2026, offering additional time for scholars and practitioners to contribute to this interdisciplinary conversation. Registration is now open, and further details are available at www.ucd.ie/robophilosophy2026/.

Guest Lecture by Luca M. Leisten

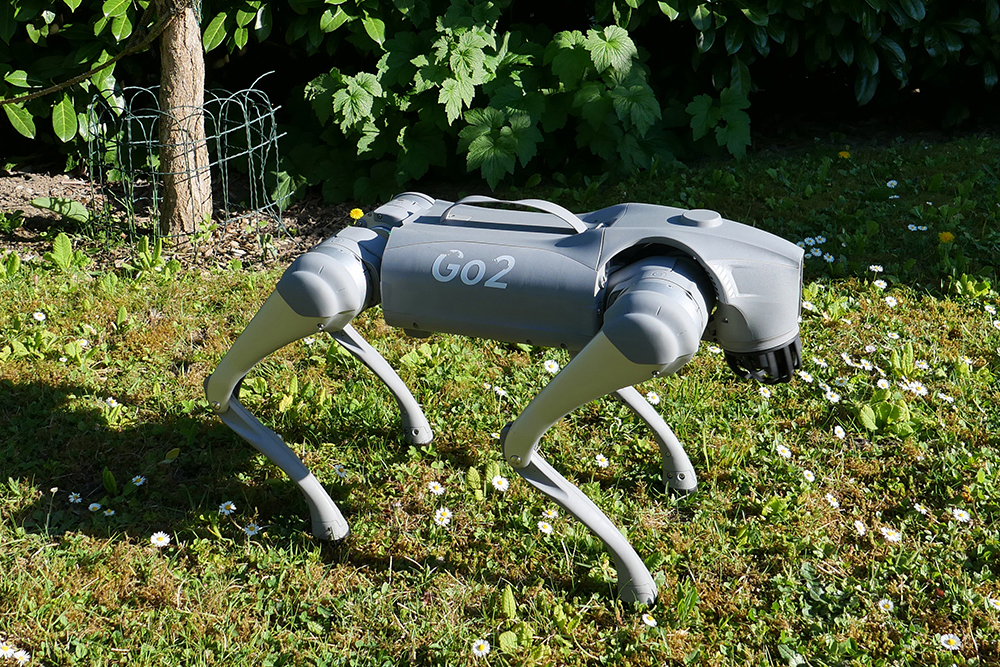
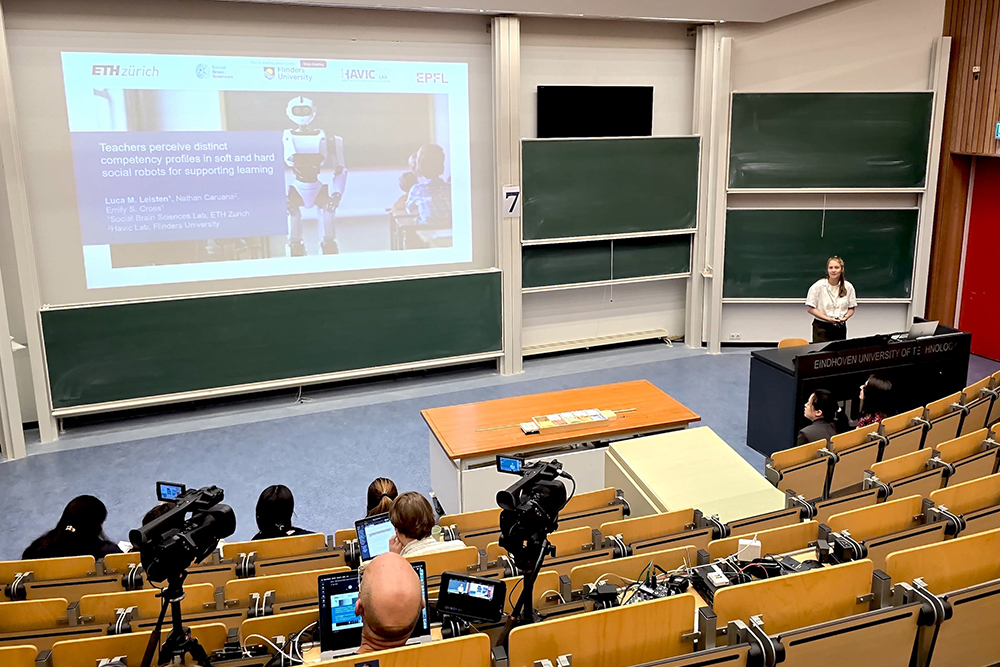
The elective module “Soziale Roboter” by Prof. Dr. Oliver Bendel will be held again from March 30 to April 1, 2026, at FHNW in Olten. It is primarily aimed at prospective business AI students, but students of information systems can also take part. Luca Marie Leisten has been invited as a guest speaker.  She is a third-year doctoral student in learning sciences and human-robot interaction at ETHZ and EPFL. With a background in psychology and social sciences, Luca’s research focuses on social robot companions in the learning domain. Specifically, she is interested in investigating the barriers and opportunities of social robot deployment as well as the perception of different robots. In this context, Luca is testing the long-term effects of affordable DIY robotic toolkits using a mix of quantitative and qualitative methods. Unitree Go2, Alpha Mini, Cozmo, Vector, AIBI, Eilik, Furby, Booboo, and Hugvie from Oliver Bendel’s private Social Robots Lab will also be on site. Social Robotics Girl, a so-called GPT specializing in this topic, will be available as a tutor throughout the event. Key works include “Soziale Roboter” (2021) and “300 Keywords Soziale Robotik” (2021). At the end of the elective module, students design social robots – also with the help of generative AI – that they find useful, meaningful, or simply attractive. The elective module has been offered since 2021 and is very popular at the university.

New Perspectives on Queering Sex Robots

A new article titled “Queering Sex Robots Beyond Diversifying Design? Insights from Queer Lacanian Psychoanalysis and New Materialism” (van der Horst & Puzio, 2026) has been published in Philosophy & Technology. The authors argue that queering sex robots should go beyond diversifying their physical design and instead involve a broader reconsideration of sexuality, identity, and human-technology relations. The paper starts from a critique widely discussed in the literature: current sex robot models largely reproduce heteronormative and stereotypical representations of femininity. Similar observations and related arguments can be found in earlier contributions in the volume “Maschinenliebe” (Bendel 2020). In that book, Tanja Kubes addresses the topic in her chapter “Queere Sexroboter”, while Oliver Bendel discusses transformations of gender and embodiment in “Trans-Formers”. Both contributions also refer to examples such as the Harmony robot from Realbotix/RealDollX. The main novelty of the new article lies in its theoretical framework, which combines Queer Lacanian psychoanalysis and New Materialism. Given the thematic overlap and the small number of publications on queer perspectives on sex robots, it is somewhat surprising that the earlier contributions in “Maschinenliebe” are not referenced. This book is predominantly written in German, but in times of large language models this should hardly pose a barrier. Moreover, the chapters by Kubes and Bendel have already been cited in several English-language academic publications (Photo: Cybrothel).

A Virtual Buddy for Inmates

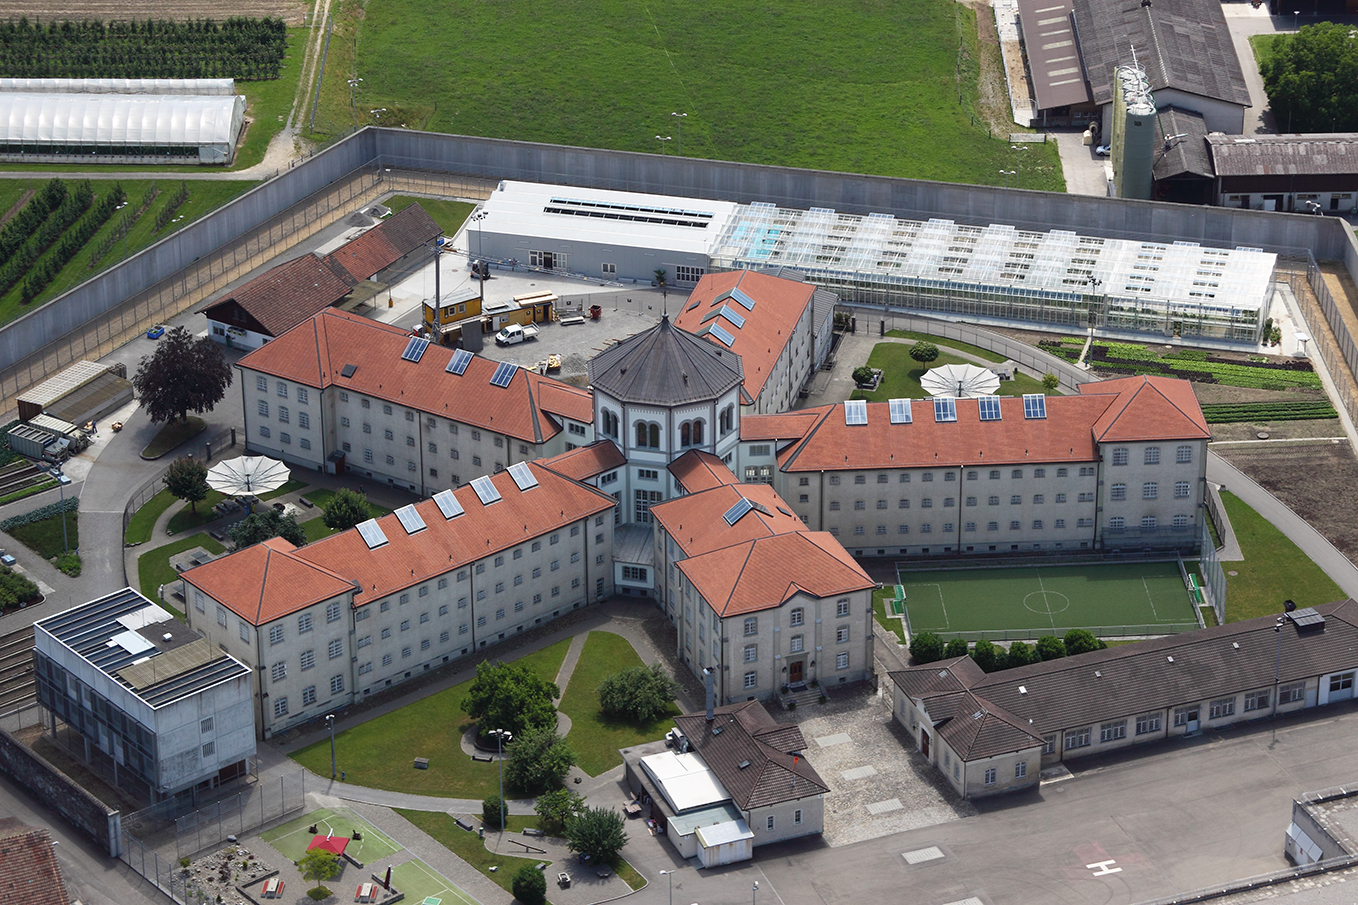
Inmates in Swiss correctional facilities have only limited access to digital technologies and little contact with the outside world. At the same time, they spend several hours each day in their cells. The project “Chatbots for Inmates” (short title) aims to address this situation: an LLM-based chatbot is intended to serve as a virtual buddy that enables conversations, reduces loneliness, and strengthens social and digital skills. The project was initiated by Tamara Siegmann, founder of the start-up SIEG – Smart Innovation Engineering Group by Siegmann and a student at the FHNW School of Business. She serves as project leader; Prof. Dr. Oliver Bendel is responsible for the project, and Stephan Vonschallen is a project collaborator. The application partner is Lenzburg Prison (JVA Lenzburg), represented by its director Marcel Ruf. The chatbot will run offline on tablets used by the inmates. In a pilot phase, the solution will initially be tested on two or three tablets and later on 30 tablets. The project will investigate whether a digital conversational partner can improve inmates’ well-being and support them in developing skills for life after release. The project began on March 1, 2026, and is supported by an innovation voucher (Innoscheck) from Innosuisse as well as by the Institute for Information Systems at the FHNW School of Business. Back in 2024, Tamara Siegmann and Oliver Bendel carried out a project on Swiss prisons, investigating whether collaborative and social robots could and should be used there. The paper can be downloaded or purchased here (Photo: Boehlich, Wikimedia, CC0 1.0 Universal).

WhereIsIt: An Object-Location Reminder

Blind and severely visually impaired people depend in everyday life on systematically placing objects or remembering their location. Because visual control is lacking, everyday items such as keys, medication, documents, or technical aids are often misplaced or must be searched for with considerable effort. This leads to loss of time, stress, and unnecessary dependence on other people. Existing solutions such as Microsoft’s “Find My Things” often rely on visual object recognition or complex assistance systems. These are technically demanding, prone to errors, energy-intensive, and not always acceptable from a privacy perspective. What is needed is a simple, robust, and practical solution for everyday use that does not require continuous camera usage and can be operated intuitively. A speech-based object reminder assistant called WhereIsIt is being developed on the initiative of Prof. Dr. Oliver Bendel. The user can use voice input to record which object has been placed where (e.g., “I put my medication on the kitchen table”). The information is stored locally and provided with a timestamp. When asked later (“Where is my medication?”), the system outputs the last known location via speech. Optionally, inexpensive Bluetooth tags can be used that emit an additional acoustic signal to make the object physically easier to locate. The focus is on ease of use, low technical complexity, and high reliability. Possible technical components include: voice capture and speech recognition; extraction of object and location information; local data storage with time reference; voice-based feedback; optional integration of BLE tags. When AI components are used, it is a project within Inclusive AI. The kick-off meeting will take place on March 17, 2026 at the FHNW School of Business. Damian Huckele has been recruited to implement the project.

SAGA: Sexuality and Generative AI

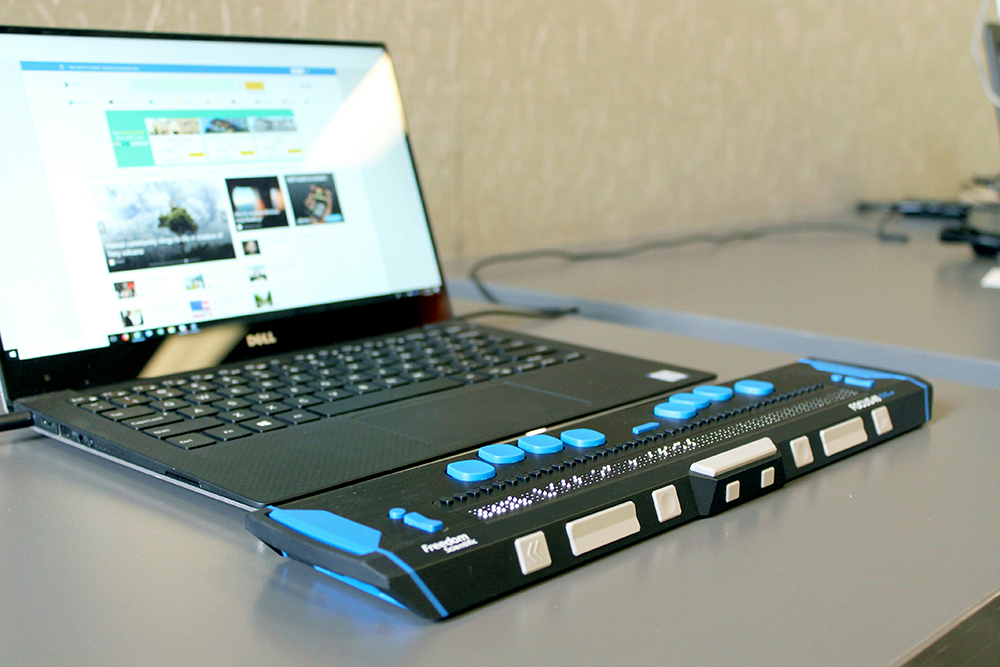
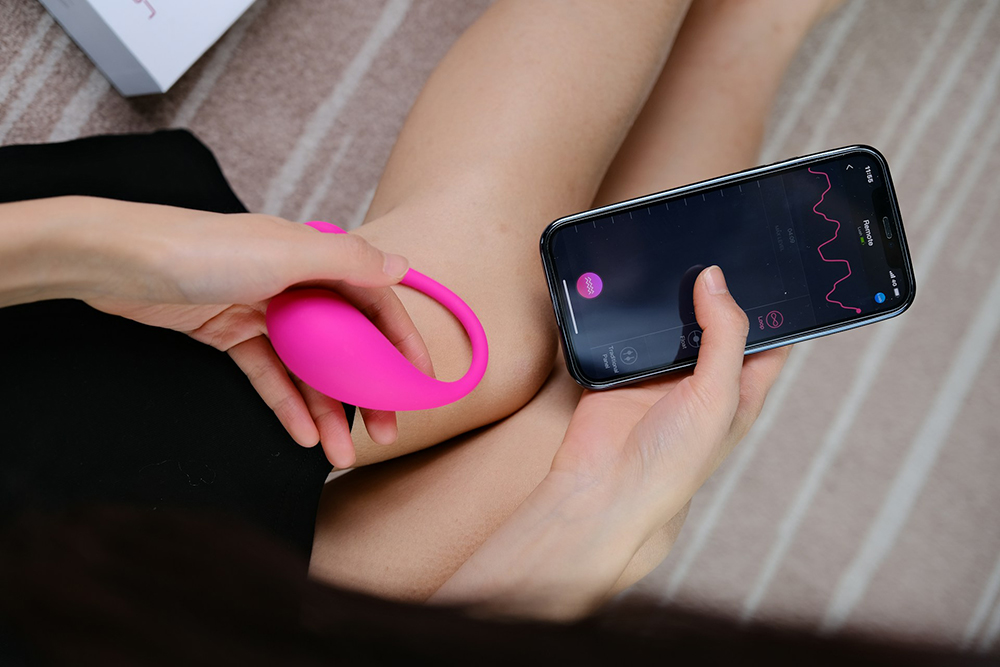
The upcoming “SAGA: Sexuality and Generative AI” symposium, taking place on April 30, 2026 at the Université du Québec à Montréal, explores how generative AI is reshaping intimacy, desire, relationships, and sexual expression. The presentation by Prof. Dr. Oliver Bendel begins with the Tamagotchi, the iconic digital pet that demonstrated how simple interactive systems can evoke emotional attachment. It then turns to social robots, wearable social robots, and AI-enhanced sex toys, love dolls, and sex robots. Today, large language models (LLMs) and multimodal language models (MLLMs) enable dialogue, perception, and evaluation in these systems. Such capabilities may also benefit people with disabilities, including blind users, by facilitating communication and interaction. At the same time, the physical dimension remains crucial. Embodied systems create presence and proximity: they can be touched, held, and stroked, and experienced through movement, vibration, or sound. The talk argues that future intimate technologies will emerge from the convergence of generative intelligence and physical embodiment, combining conversational AI with the sensory experience of a physically present companion. Full details and submissions are available at event.fourwaves.com/sexualiteia/pages.