Investigating Robot Enhancement
Social robots and service robots usually have a defined locomotor system, a defined appearance and defined mimic and gestural abilities. This leads, on the one hand, to a certain familiarization effect. On the other hand, the actions of the robots are thus limited, for example in the household or in a shopping mall. Robot enhancement is used to extend and improve social robots and service robots. It changes their appearance and expands their scope. It is possible to apply attachments to the hardware, extend limbs and exchange components. One can pull skin made of silicone over the face or head, making the robots look humanoid. One can also change the software and connect the robot to AI systems – this is already done many times. The project or thesis, announced by Oliver Bendel in August 2020 at the School of Business FHNW, should first present the principles and functional possibilities of robot enhancement. Second, concrete examples should be given and described. One of these examples, e.g., the skin made of silicone, has to be implemented. Robots like Pepper or Atlas would be completely changed by such a skin. They could look uncanny, but also appealing. The project will start in September 2020.

Launch of the Interactive AI Magazine

AAAI has announced the launch of the Interactive AI Magazine. According to the organization, the new platform provides online access to articles and columns from AI Magazine, as well as news and articles from AI Topics and other materials from AAAI. “Interactive AI Magazine is a work in progress. We plan to add lot more content on the ecosystem of AI beyond the technical progress represented by the AAAI conference, such as AI applications, AI industry, education in AI, AI ethics, and AI and society, as well as conference calendars and reports, honors and awards, classifieds, obituaries, etc. We also plan to add multimedia such as blogs and podcasts, and make the website more interactive, for example, by enabling commentary on posted articles. We hope that over time Interactive AI Magazine will become both an important source of information on AI and an online forum for conversations among the AI community.” (AAAI Press Release) More information via interactiveaimag.org.

Next ROBOPHILOSOPHY in Helsinki

One of the world’s most important conferences for robot philosophy (aka robophilosophy) and social robotics, ROBOPHILOSOPHY, took place from 18 to 21 August 2020, not in Aarhus (Denmark) as originally planned, but – due to the COVID 19 pandemic – in virtual form. Organizers and presenters were Marco Nørskov and Johanna Seibt. A considerable number of the lectures were devoted to machine ethics, such as “Moral Machines” (Aleksandra Kornienko), “Permissibility-Under-a-Description Reasoning for Deontological Robots” (Felix Lindner) and “The Morality Menu Project” (Oliver Bendel). The keynotes were given by Selma Šabanović (Indiana University Bloomington), Robert Sparrow (Monash University), Shannon Vallor (The University of Edinburgh), Alan Winfield (University of the West of England), Aimee van Wynsberghe (Delft University of Technology) and John Danaher (National University of Ireland). In his outstanding presentation, Winfield was sceptical about moral machines, whereupon Bendel made it clear in the discussion that they are useful in some areas and dangerous in others, and emphasized the importance of machine ethics for the study of machine and human morality, a point with which Winfield again agreed. The last conference was held in Vienna in 2018. Keynote speakers at that time included Hiroshi Ishiguro, Joanna Bryson and Oliver Bendel. The next ROBOPHILOSOPHY will probably take place in 2022 at the University of Helsinki, as the organisers announced at the end of the event.

3D Printing a Robotic Finger

Nao and Pepper have perfectly shaped hands and fingers. But the fingers are now facing serious competition. Scientists at University of California- Santa Cruz and Ritsumeikan University in Japan have designed and produced a robotic finger inspired by the human endoskeletal structure. From the abstract of the paper “3D Printing an Assembled Biomimetic Robotic Finger”: “We present a novel approach for fabricating cable-driven robotic systems. Particularly, we show that a biomimetic finger featuring accurate bone geometry, ligament structures, and viscoelastic tendons can be synthesized as a single part using a mutli-material 3D printer. This fabrication method eliminates the need to engineer an interface between the rigid skeletal structure and elastic tendon system. The artificial muscles required to drive the printed tendons of the finger can also be printed in place.” The biomimetic robotic finger was presented at the 17th International Conference on Ubiquitous Robots (UR). The paper is available here.

The MOML Project

In many cases it is important that an autonomous system acts and reacts adequately from a moral point of view. There are some artifacts of machine ethics, e.g., GOODBOT or LADYBIRD by Oliver Bendel or Nao as a care robot by Susan Leigh and Michael Anderson. But there is no standardization in the field of moral machines yet. The MOML project, initiated by Oliver Bendel, is trying to work in this direction. In the management summary of his bachelor thesis Simon Giller writes: “We present a literature review in the areas of machine ethics and markup languages which shaped the proposed morality markup language (MOML). To overcome the most substantial problem of varying moral concepts, MOML uses the idea of the morality menu. The menu lets humans define moral rules and transfer them to an autonomous system to create a proxy morality. Analysing MOML excerpts allowed us to develop an XML schema which we then tested in a test scenario. The outcome is an XML based morality markup language for autonomous agents. Future projects can use this language or extend it. Using the schema, anyone can write MOML documents and validate them. Finally, we discuss new opportunities, applications and concerns related to the use of MOML. Future work could develop a controlled vocabulary or an ontology defining terms and commands for MOML.” The bachelor thesis will be publicly available in autumn 2020. It was supervised by Dr. Elzbieta Pustulka. There will also be a paper with the results next year.

Findings on Robotic Hugging

In the first part of the HUGGIE project initiated by Oliver Bendel, two students of the School of Business FHNW conducted an online survey with almost 300 participants. In the management summary of their bachelor thesis Ümmühan Korucu and Leonie Stocker (formerly Leonie Brogle) write: “The results of the survey indicated that people have a positive attitude towards robots in general as robots are perceived as interesting and useful rather than unnecessary and disturbing. However, only a minority of the participants stated that they would accept a hug from a robot. A possible reason for this could be that for the majority of participants, a hug is an act of intimacy with a deeper meaning attached to it which is only being shared with selected persons. For a robot to be perceived as an attractive hugging partner, a human-like design including a face, eyes, a friendly look as well as the ability to communicate verbally and non-verbally is desired. However, an appearance being too realistic has a deterrent effect. Furthermore, an in-depth analysis of the data in relation to age and gender of the participants resulted in the discovery of interesting facts and differences. Overall, the findings contribute to a clearer picture about the appearance and the features Huggie should have in order to be accepted as a hugging counterpart.” The bachelor thesis will be publicly available in autumn 2020. There will also be a paper with the results next year.

Ingenuity on Mars

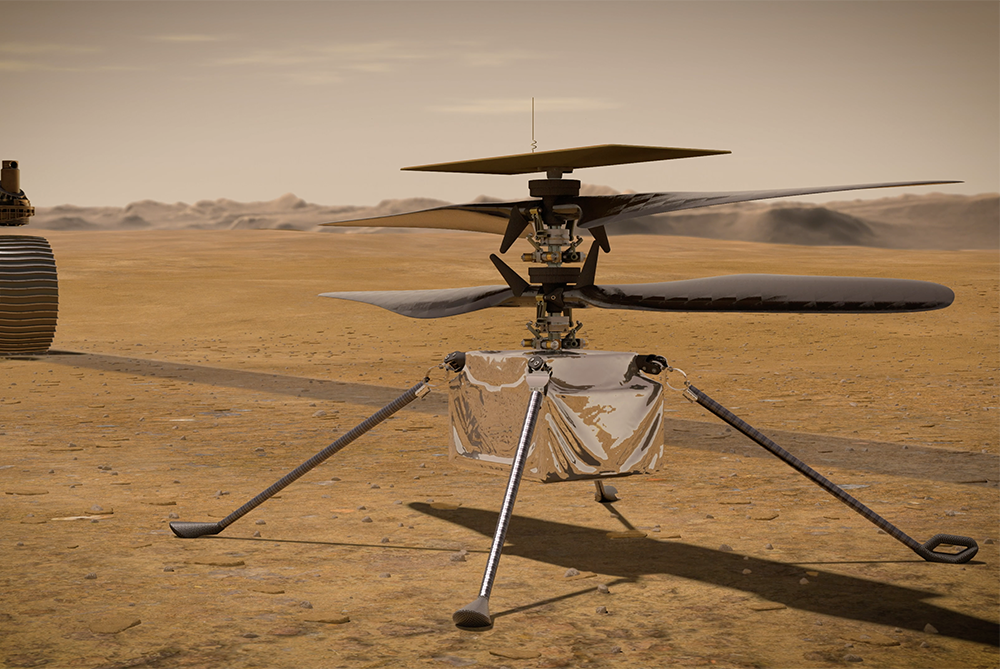
The Perseverance rover, which is on its way to Mars, is carrying a drone called Ingenuity (photo/concept: NASA). According to NASA, it is a technology demonstration to test powered flight on another world for the first time. “A series of flight tests will be performed over a 30-Martian-day experimental window that will begin sometime in the spring of 2021. For the very first flight, the helicopter will take off a few feet from the ground, hover in the air for about 20 to 30 seconds, and land. That will be a major milestone: the very first powered flight in the extremely thin atmosphere of Mars! After that, the team will attempt additional experimental flights of incrementally farther distance and greater altitude.” (Website NASA) After the drone has completed its technology demonstration, the rover will continue its scientific mission. Manned and unmanned flights to Mars will bring us several innovations, including novel chatbots and voicebots.

Four-Legged Robots to Scout Factories

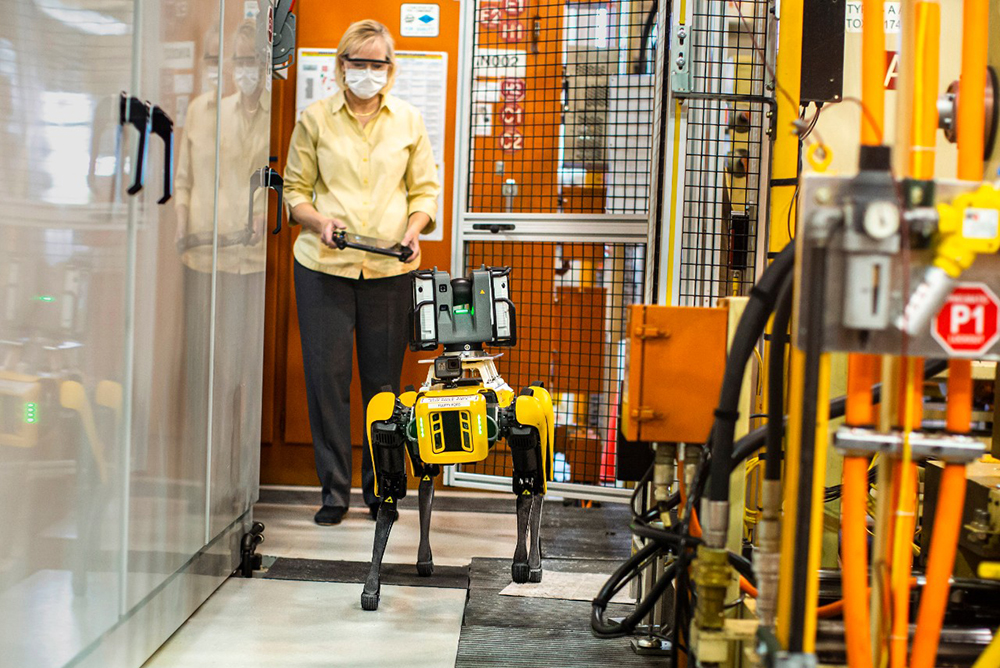
Ford experiments with four-legged robots, to scout factories. The aim is to save time and money. The Ford Media Center presented the procedure on 26 July 2020 as follows: “Ford is tapping four-legged robots at its Van Dyke Transmission Plant in early August to laser scan the plant, helping engineers update the original computer-aided design which is used when we are getting ready to retool our plants. These robots can be deployed into tough-to-reach areas within the plant to scan the area with laser scanners and high-definition cameras, collecting data used to retool plants, saving Ford engineers time and money. Ford is leasing two robots, nicknamed Fluffy and Spot, from Boston Dynamics – a company known for building sophisticated mobile robots.” (Website Ford Media Center) Typically, service robots (e.g., transport robots like Relay) scan buildings to create 2D or 3D models that help them navigate through the rooms. Shuttles use lidar systems to create live 3D models of the environment, to detect obstacles. The robots from Boston Dynamics are also mobile, and that is their great advantage (photo: Ford). Nothing can escape them, nothing can hide from them. Probably the benefit can be increased by including cameras in the building, i.e. using robot2x communication.

Chocolate Could Increase Acceptance

A multi-stage HUGGIE project is currently underway at the School of Business FHNW under the supervision of Prof. Dr. Oliver Bendel. Ümmühan Korucu and Leonie Stocker (formerly Leonie Brogle) started with an online survey. The aim was to gain insights into how people of all ages and sexes judge a hug by a robot. In crises and catastrophes involving prolonged isolation, such as the COVID 19 pandemic, proxy hugs of this kind could well play a role. Prisons and longer journeys through space are also possible fields of applications. Nearly 300 people took part in the online survey. The evaluation is almost complete and the results are remarkable. Among other things, it was found that women want to be hugged by a robot that is bigger than them, and men want to be hugged by a robot that is smaller than them. Not only the size is relevant for the acceptance of robotic hugging: “An interesting input given by one of the participants was that it could be more pleasant to hug a robot if it smelled nicely, for example like chocolate.” (Draft of Bachelor Thesis) Whether this is a typically Swiss view remains to be investigated. The results of the survey and the conclusions drawn from them for the design of HUGGIE will be compiled in a paper in the course of the year.

Talking to Harmony

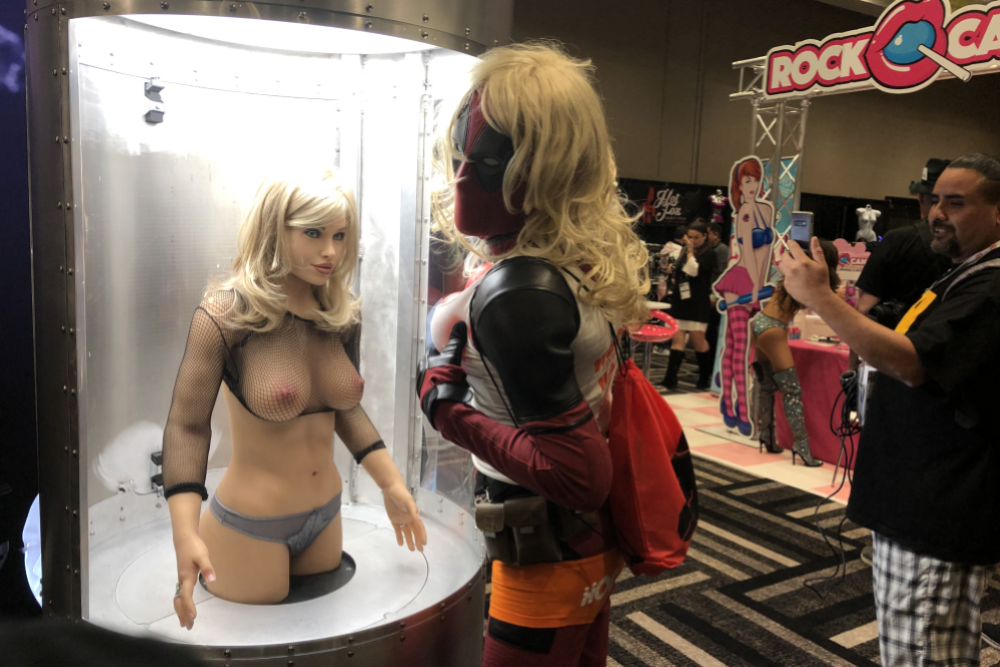
At the end of June 2020, DIE WELT conducted an interview with Prof. Dr. Oliver Bendel about sex robots and love dolls. It was especially about their natural language skills. Particularly owners and users who want to have a relationship are interested in conversations of all kinds, about God and the world and in the sense of “dirty talk”. Companies like Realbotix go very far in this respect. Harmony for example can talk to her partners for hours in a quite convincing way. The engineers experiment with GPT-2, but also with other language models. Kino Coursey, AI boss of Realbotix, deals with this topic in his article “Speaking with Harmony” for the book “Maschinenliebe” (“Machine Love”) which will be released in October. The interview with Oliver Bendel was published on 11 July 2020 in the printed edition of DIE WELT, under the title “Intelligente Sexroboter sind begehrte Gesprächspartner” (already published the day before in the electronic edition, under the title “Was Sexpuppen können” …). In addition, an English version – “Intelligent sex robots are sought-after dialogue partners” – is available.